01
4-36 mm
Diameter Classes
OD classes for compact product envelopes.
Custom micro brushless DC motors and compact assemblies reviewed around diameter, voltage, speed, load, noise, lifetime, control method, and validation evidence.
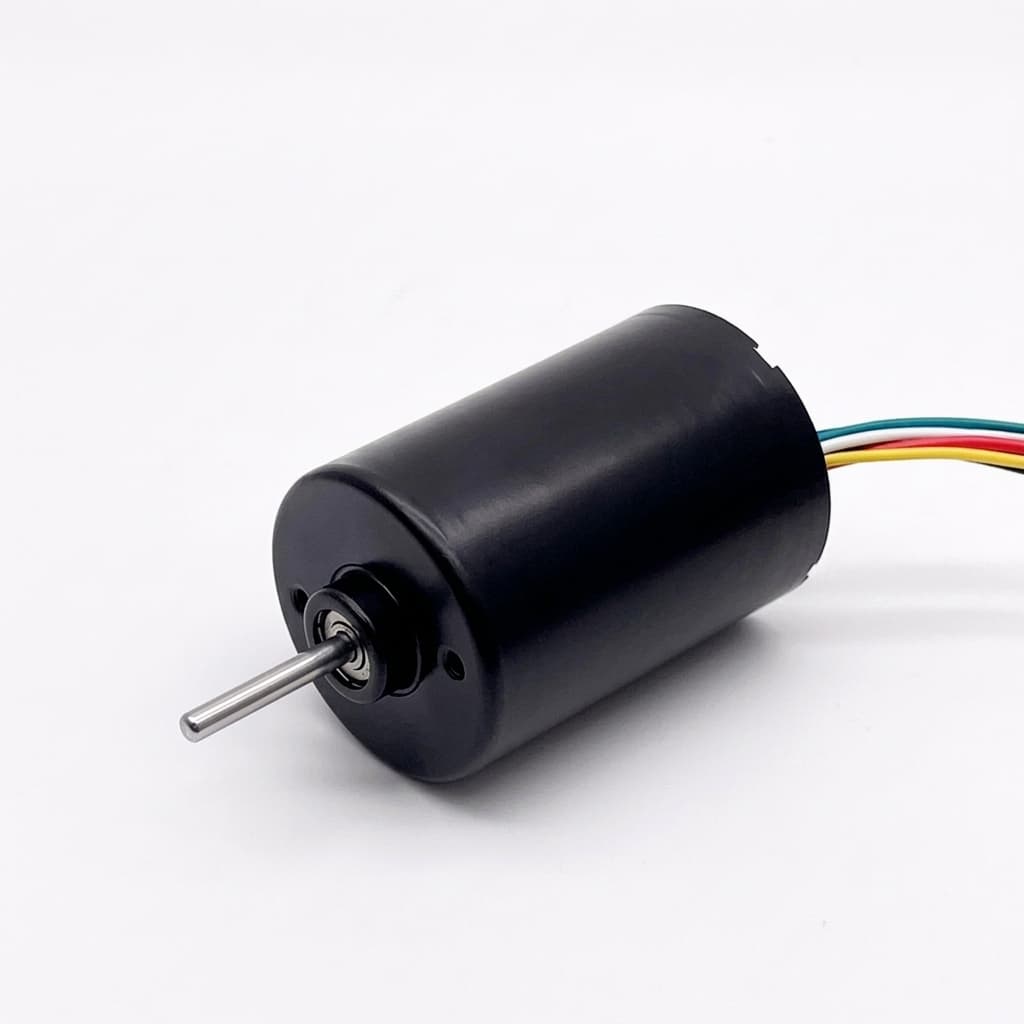
Interface review
shaft + cable + connector
Size path
micro envelope first
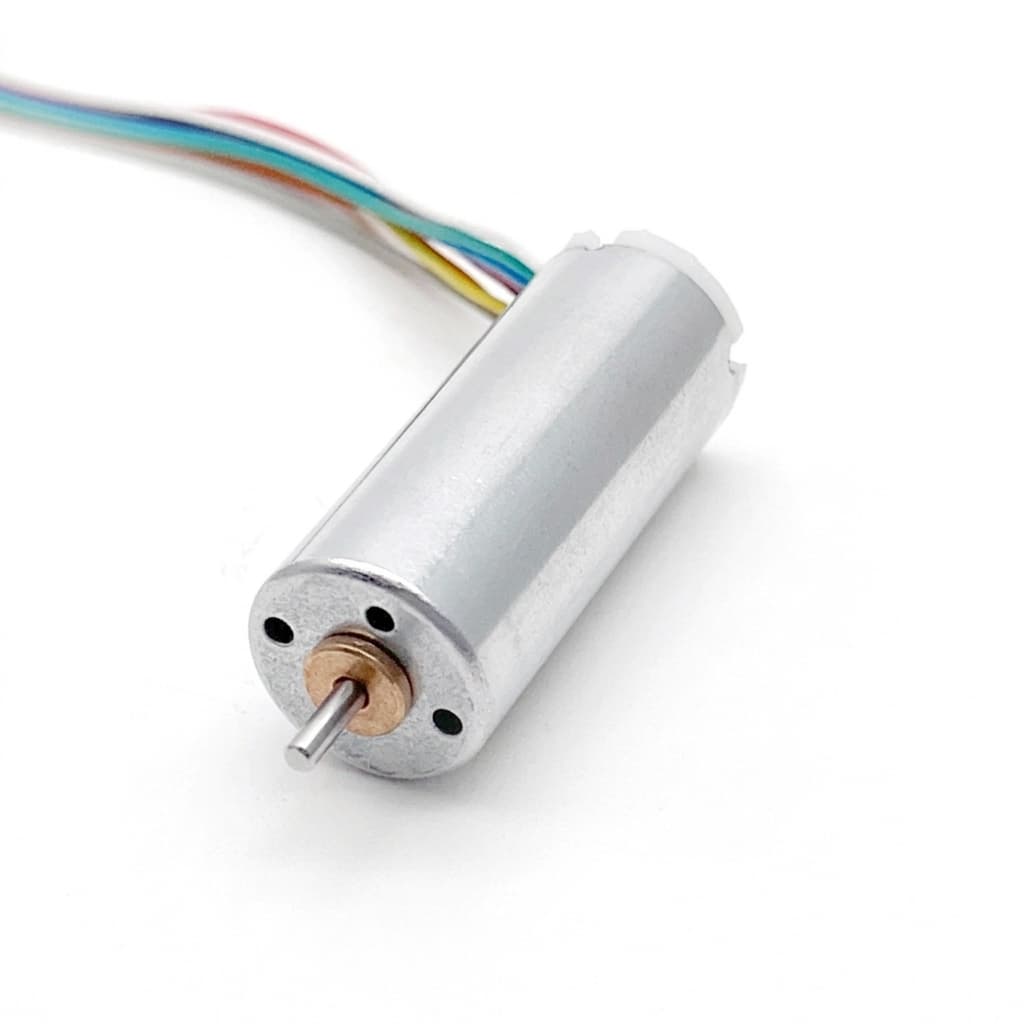
12 mm platform
compact envelope
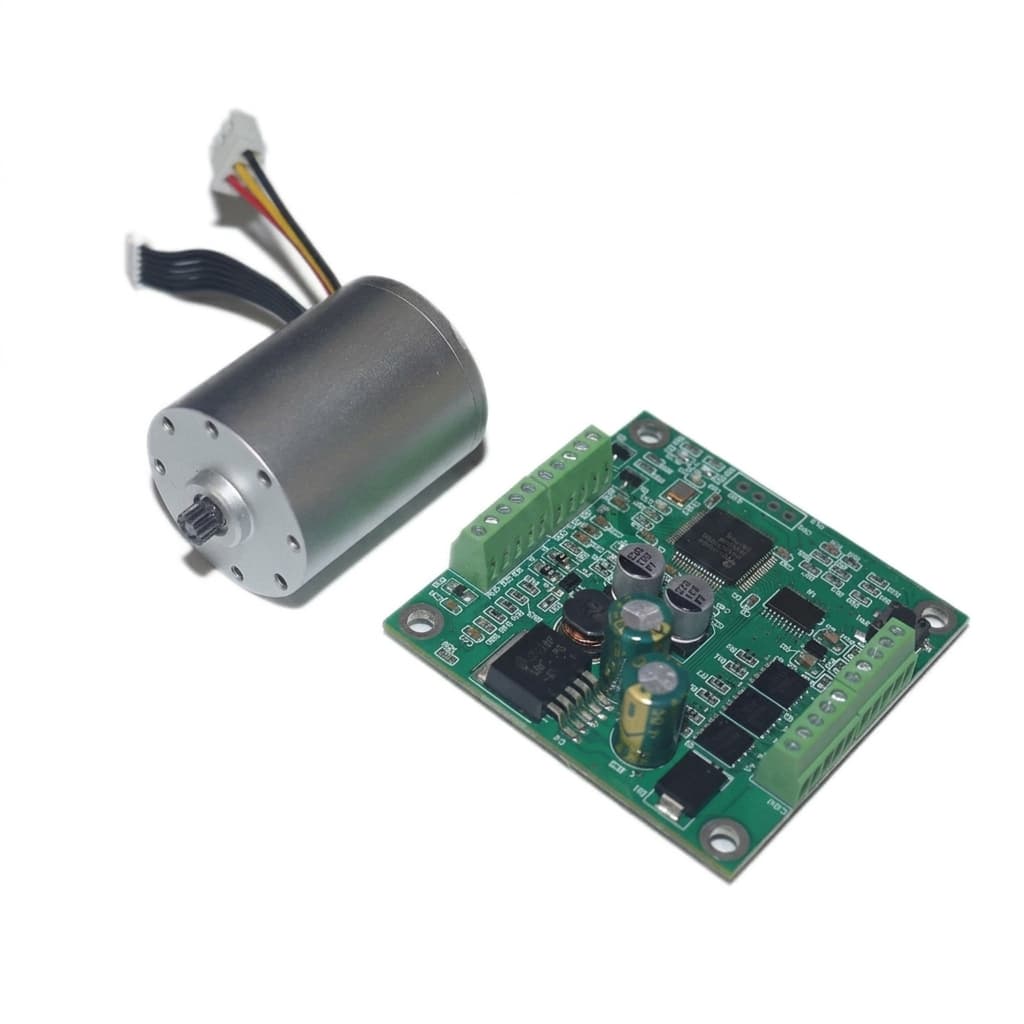
Driver option
sensorless / FOC
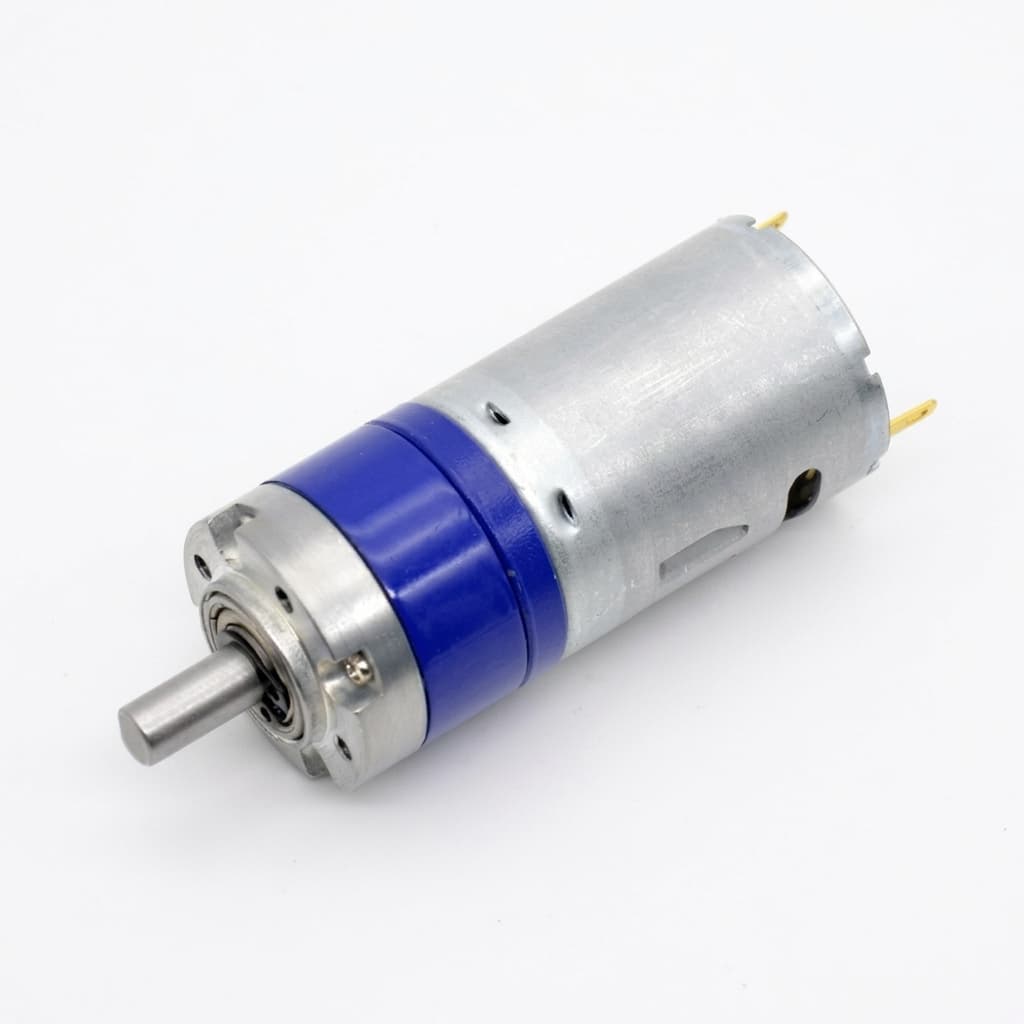
Gear path
low-speed torque
4-36 mm
Micro OD classes
FOC / Hall / encoder
Driver path review
Noise, load, life
Evidence scoped by test
Sample to pilot lot
Drawing-controlled handoff
The first sourcing discussion should expose the envelope, control path, validation scope, and production handoff risk before a custom micro BLDC sample is built.
Diameter Classes
OD classes for compact product envelopes.
Noise, Life, Load
Noise, load, thermal rise, and life checks.
Prototype, Pilot, Batch
Prototype, pilot, and repeat-supply handoff.
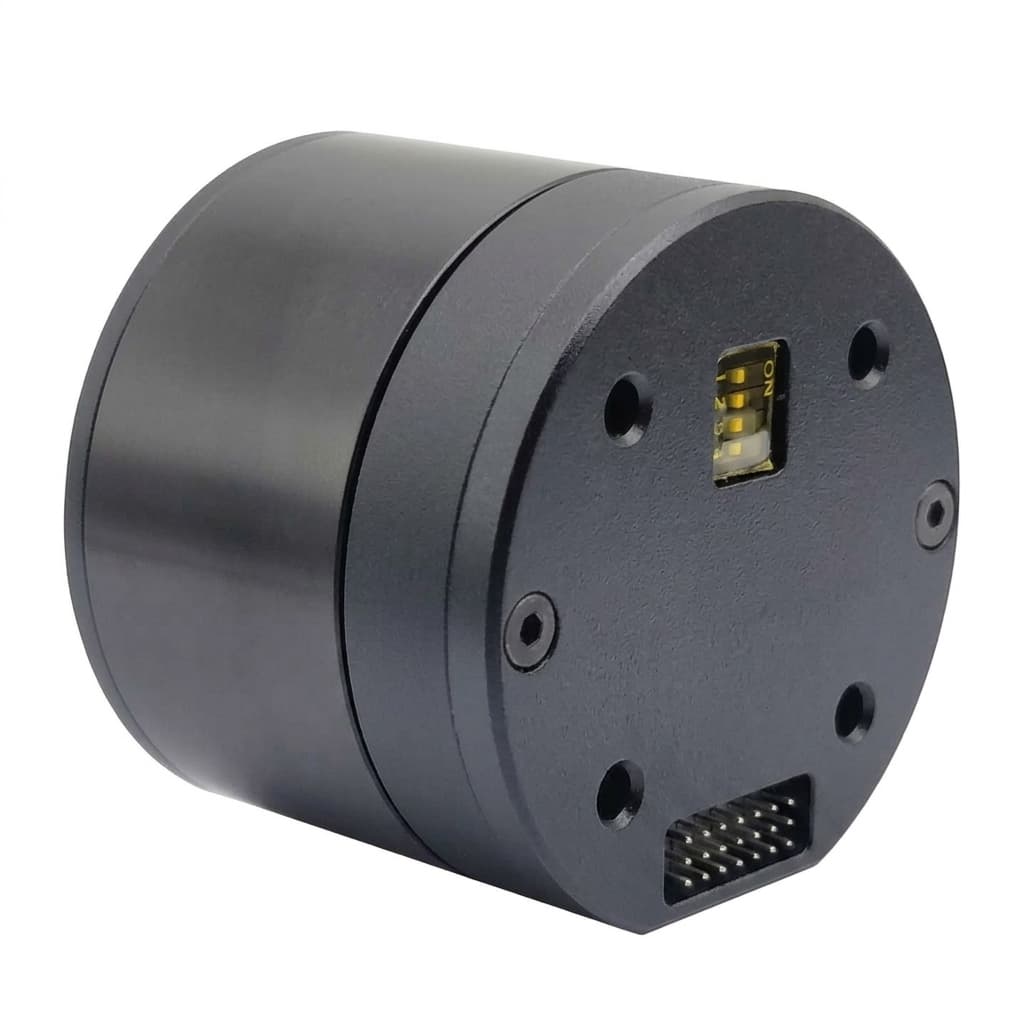
Interface
feedback + mounting
Evidence path
measured before release
Overseas engineering and sourcing teams usually need the same answers first: what size range is feasible, which interfaces can change, how quality is checked, and what must be fixed before samples move into a pilot lot.
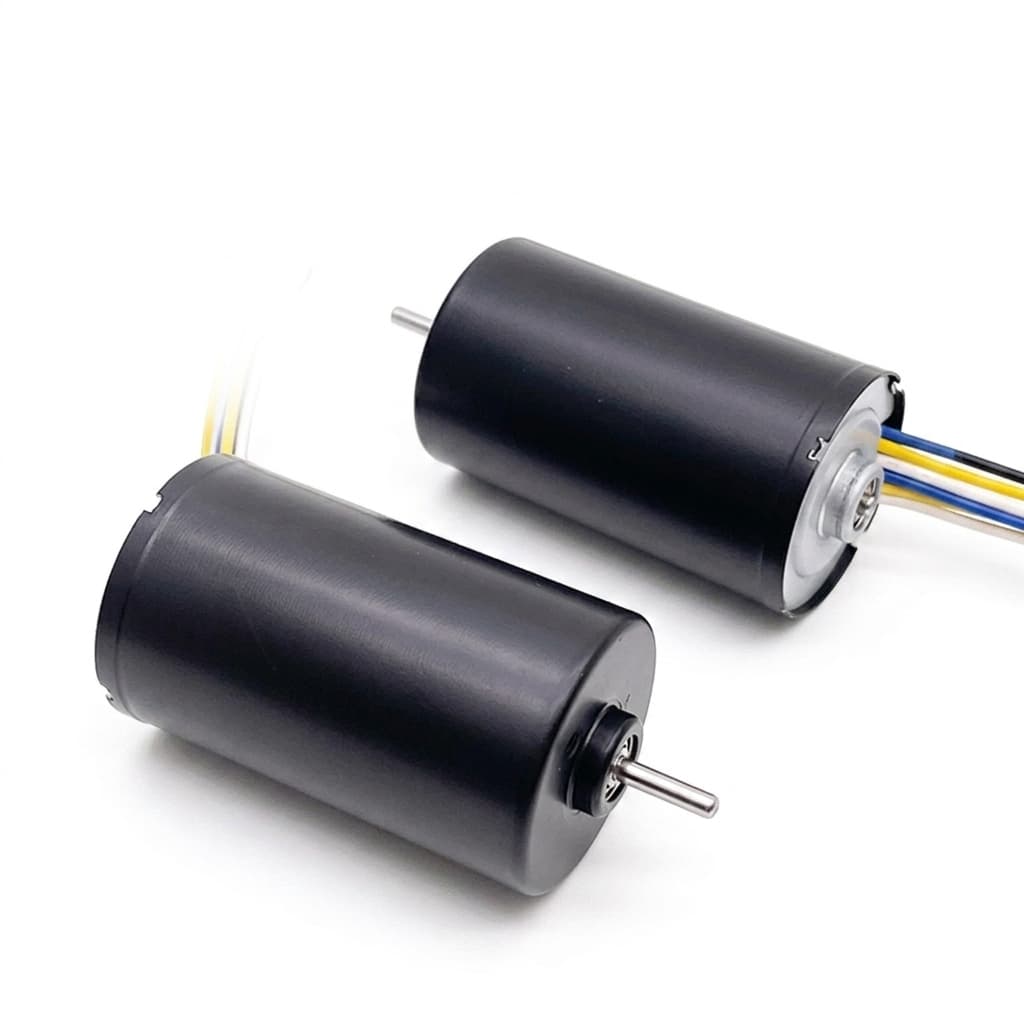
Reference sample
compare fit before tooling
Custom scope
winding + shaft + cable
Buyer output
Clear sample scope
Factory output
Evidence-ready path
Motor platform fit
Micro BLDC and micro brushless DC motors are selected around the real envelope, load, speed, and thermal limits of the device.
Interface control
Engineering changes focus on the parts that determine fit, control behavior, assembly work, and repeat production consistency.
Validation evidence
Performance claims are handled as testable requirements with stated load, fixture, distance, duty cycle, and acceptance criteria.
Sample to repeat supply
Lead-time planning starts after the drawing, reference sample, validation scope, and commercial forecast are clear.
Buyers rarely need a generic catalog wall first. The homepage now routes medical, UAV, driver-integrated, and custom OEM programs by the constraints that actually determine sample success.
Medical smoothness
slotless / coreless
UAV weight path
KV / heat / vibration
Driver integration
FOC / sensorless
OEM assembly
shaft / harness / gearbox
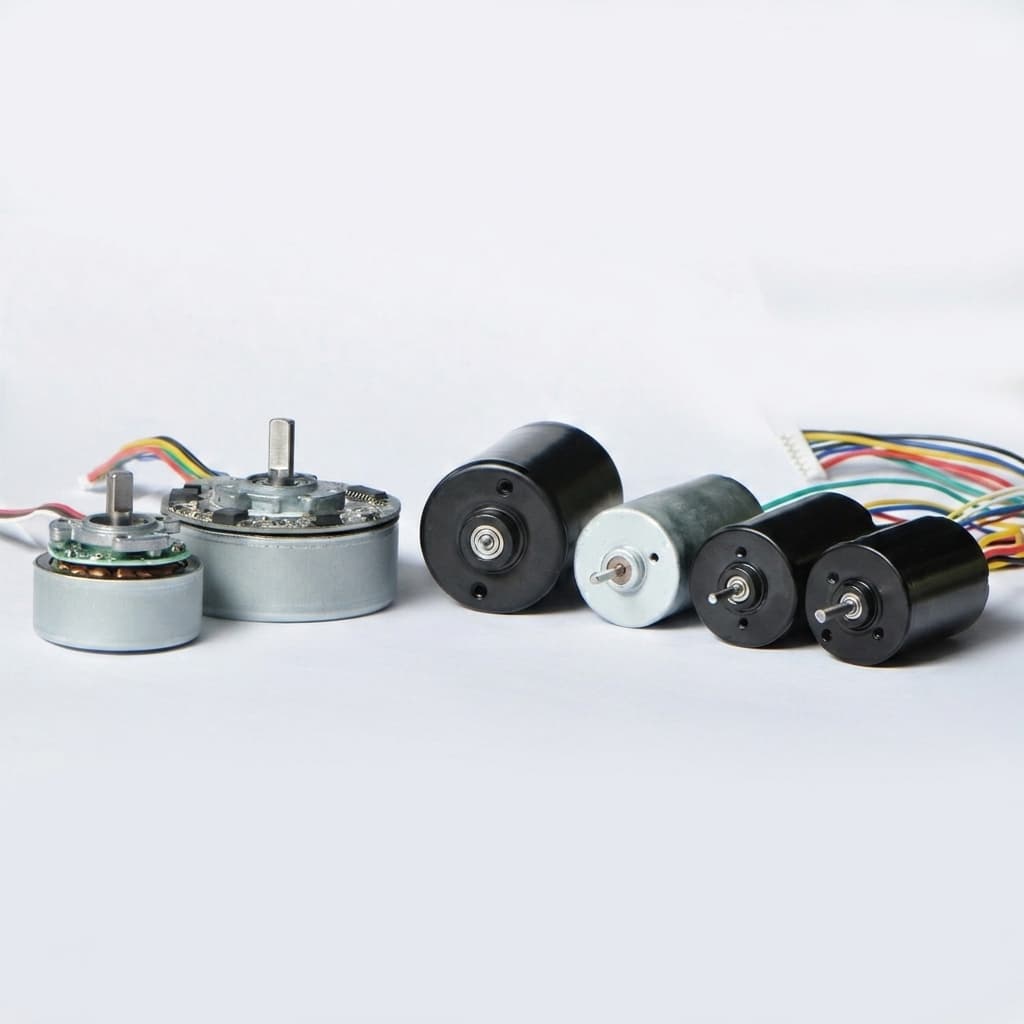
Diameter and handpiece envelope
Smooth slotless platforms for medical and dental teams reviewing low cogging, low vibration, sterilization exposure, and documented sample validation.
Typical check
8 mm, 12 mm, 16 mm, or project-specific OD and length after drawing review
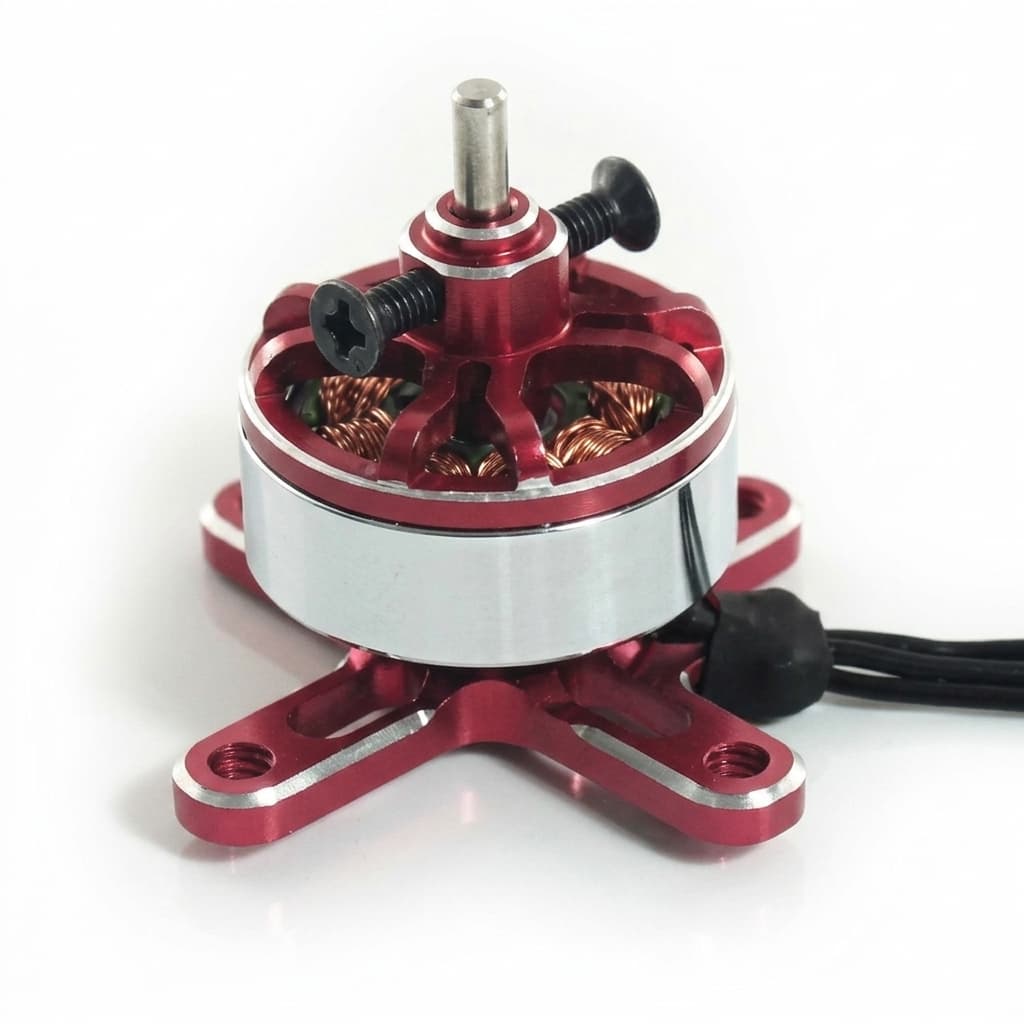
Weight and size class
Weight-sensitive outrunner and propulsion paths for FPV, micro UAV, and drone buyers balancing KV, thrust, heat rise, and vibration risk.
Typical check
0802, 1002, 1102, or custom micro outrunner envelope after drawing/sample review
Control interface
Motor-plus-driver options for compact devices that need quieter commutation, soft start, speed regulation, and fewer integration surprises.
Typical check
PWM, analog voltage, UART, I2C, enable, direction, tach, or project-specific command set
Assembly boundary
Motor-plus-interface builds covering gearbox, feedback, driver, cable, connector, harness, shaft, flange, and mounting details.
Typical check
Motor-only, motor + gearbox, motor + feedback, motor + driver, or motor + harness module
Diameter class
Compact brushless DC motor platforms for buyers checking envelope, load, acoustic noise, lifetime, and stable electronic speed control.
Typical check
4 mm to 36 mm outside diameter, project-specific length
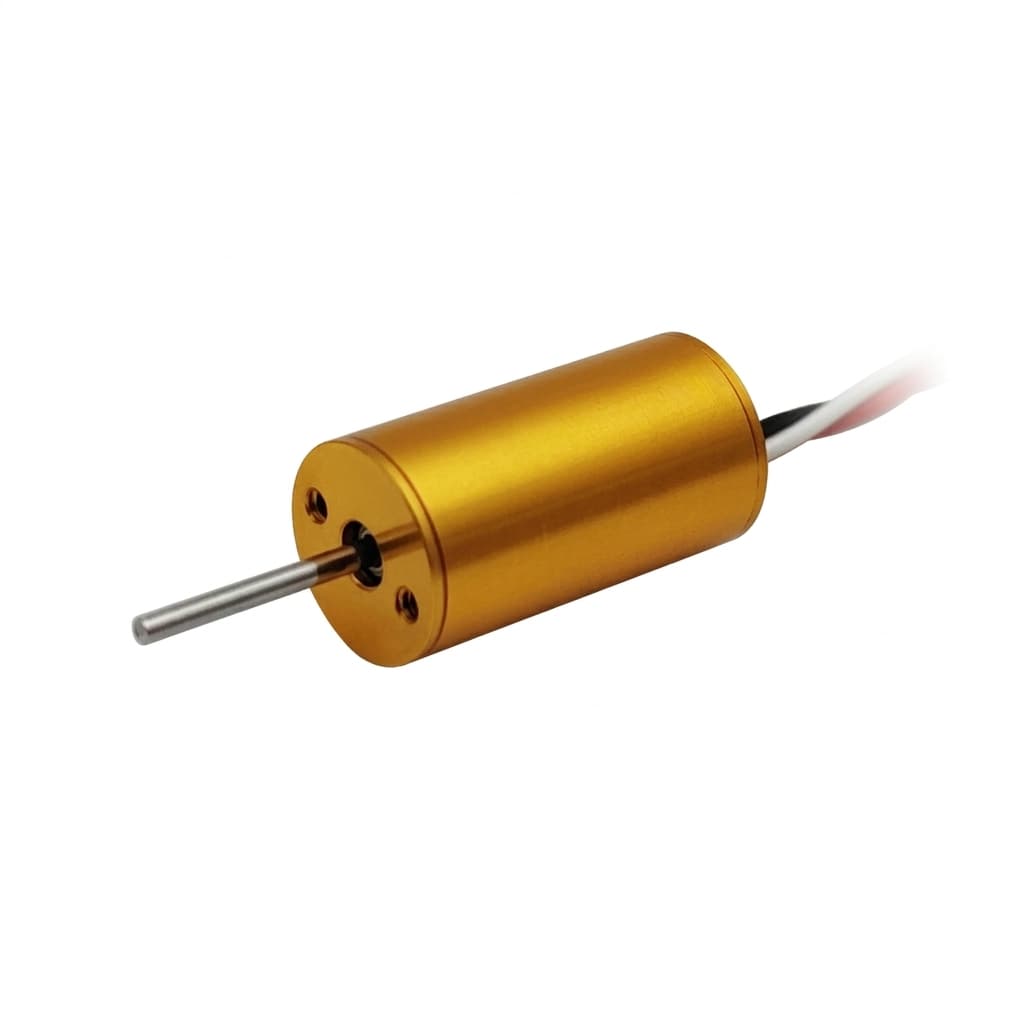
Noise
Micro BLDC motor selection for portable medical devices, handheld tools, pumps, diagnostic modules, and other applications where noise, vibration, and lifetime are purchasing risks.
Typical check
Project-specific dBA target
Engineering Support Buyers Actually Need
Engineering teams need fast feasibility review, exact fit, measurable validation, and a stable handoff from samples to repeat production.
Share diameter, length, voltage, RPM, load, current, and duty cycle so engineering can identify a realistic platform before sample cost is spent.
Winding, shaft, flange, bearing, cable, connector, Hall sensor, encoder, driver, and harness details can be reviewed against the final device envelope.
Noise, vibration, speed, load, current, temperature rise, lifetime, and start-stop checks are framed with test conditions and acceptance criteria.
After sample approval, drawings, inspection points, packaging, pilot-lot feedback, and repeat-order requirements are locked before batch supply.
Micro motor projects fail when size, controller behavior, noise targets, or fixtures are left vague until after samples arrive. The homepage now makes the review path explicit for engineering and procurement teams.
Send RFQ ParametersSend the application, diameter and length limits, voltage, speed, load, current limit, duty cycle, and target quantity.
Feasibility notes, missing parameters, and a practical motor family direction.
Confirm winding, shaft, feedback, connector, bearing, cable, controller, and validation method before custom samples.
A controlled sample scope instead of a vague catalog substitution.
Measure agreed speed, current, load behavior, noise, vibration, temperature rise, and endurance items under stated conditions.
Sample feedback that can be compared with buyer-side device testing.
Lock drawings, inspection records, packaging, export details, and lead-time assumptions before moving into batch orders.
A production handoff path with fewer late interface or quality surprises.
A short but complete RFQ lets engineering check feasibility, validation risk, and lead-time assumptions before suggesting a standard platform or custom sample build.
Use-case pages connect the motor choice to acoustic noise, vibration, speed stability, service life, and integration risk in the final product.
5
priority paths
noise + heat
validation lens
RFQ ready
checklist route
Low-noise, long-life micro BLDC motor sourcing for portable medical devices, pumps, handheld instruments, diagnostics, and therapy modules.
Buyer check
Noise target: Defined by dBA method
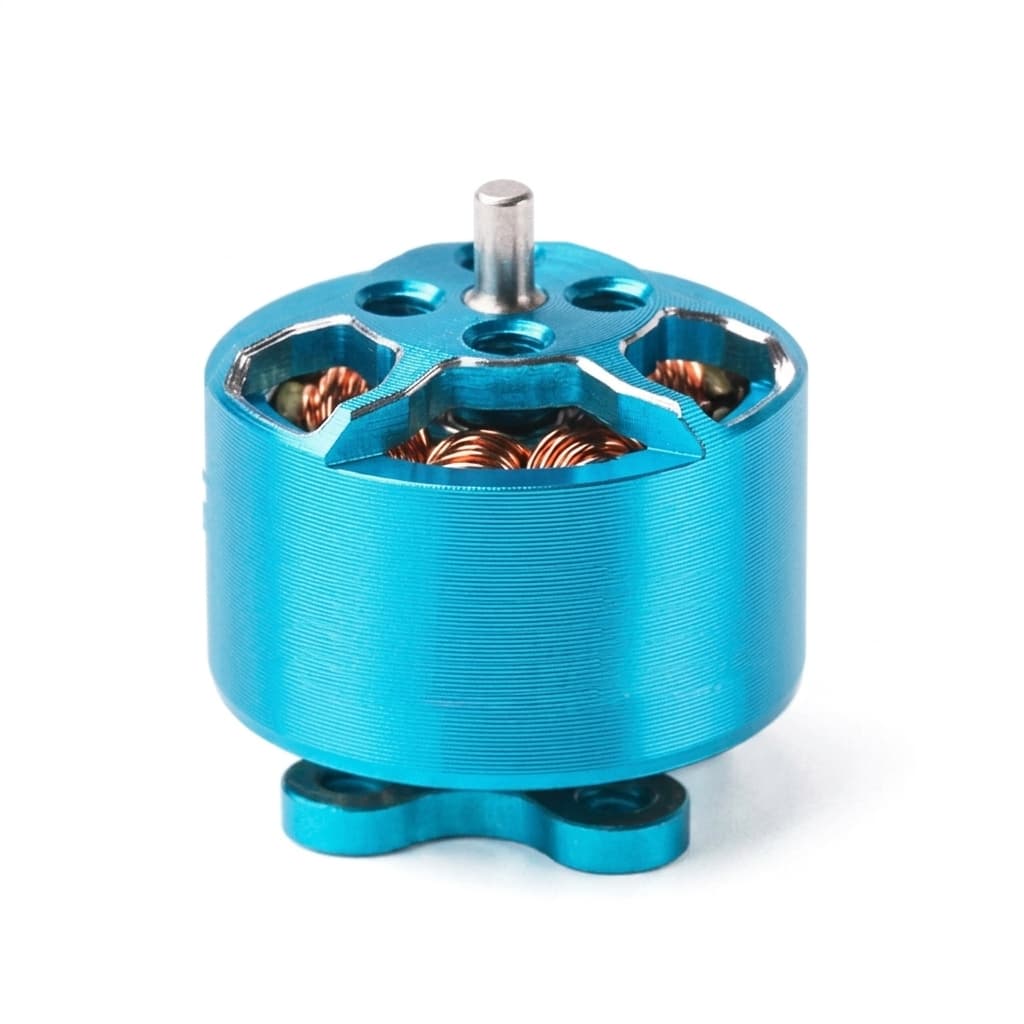
High-speed, lightweight micro BLDC motor support for micro UAV propulsion, compact fans, gimbals, and vibration-sensitive drone assemblies.
Buyer check
Rotor balance: Application-specific
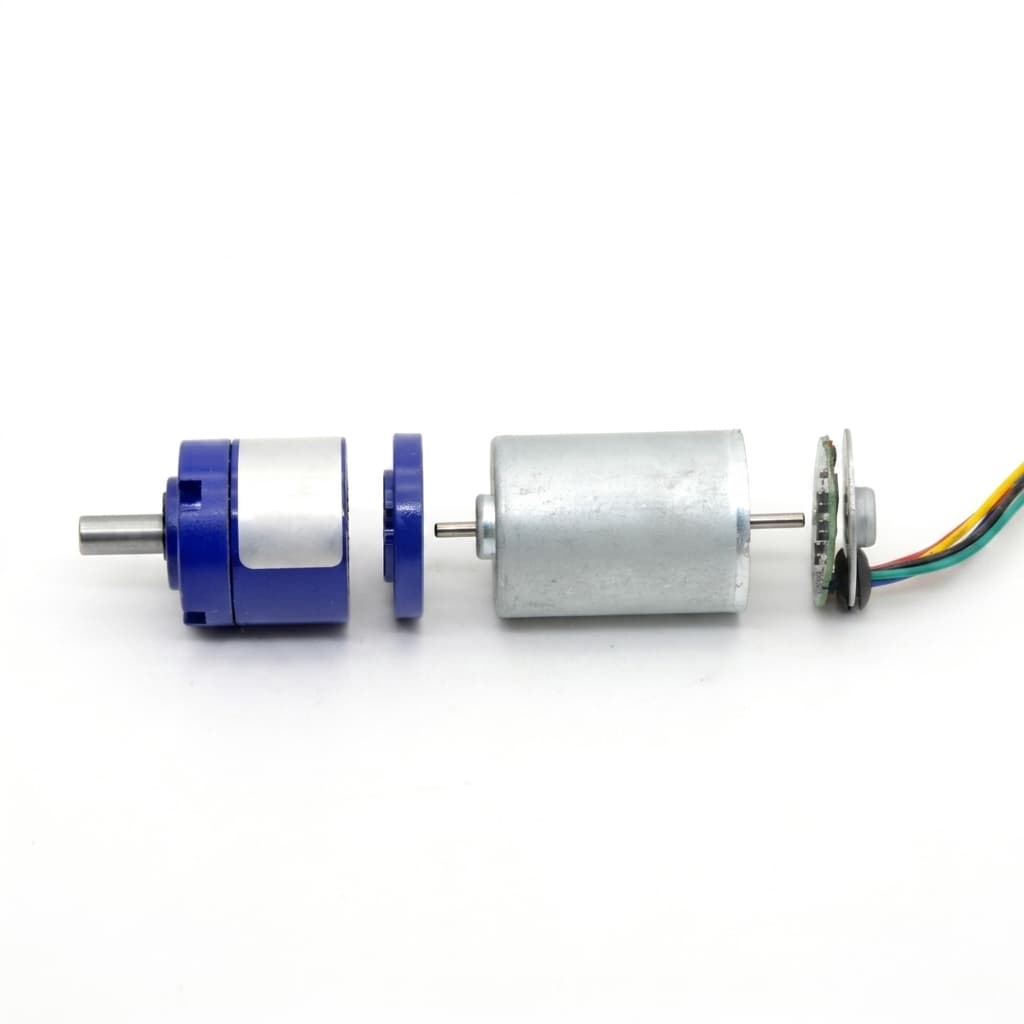
Micro BLDC motor sourcing for high-end small appliances, personal care devices, quiet fans, blowers, pumps, and compact smart home mechanisms.
Buyer check
Speed stability: Defined by controller and load
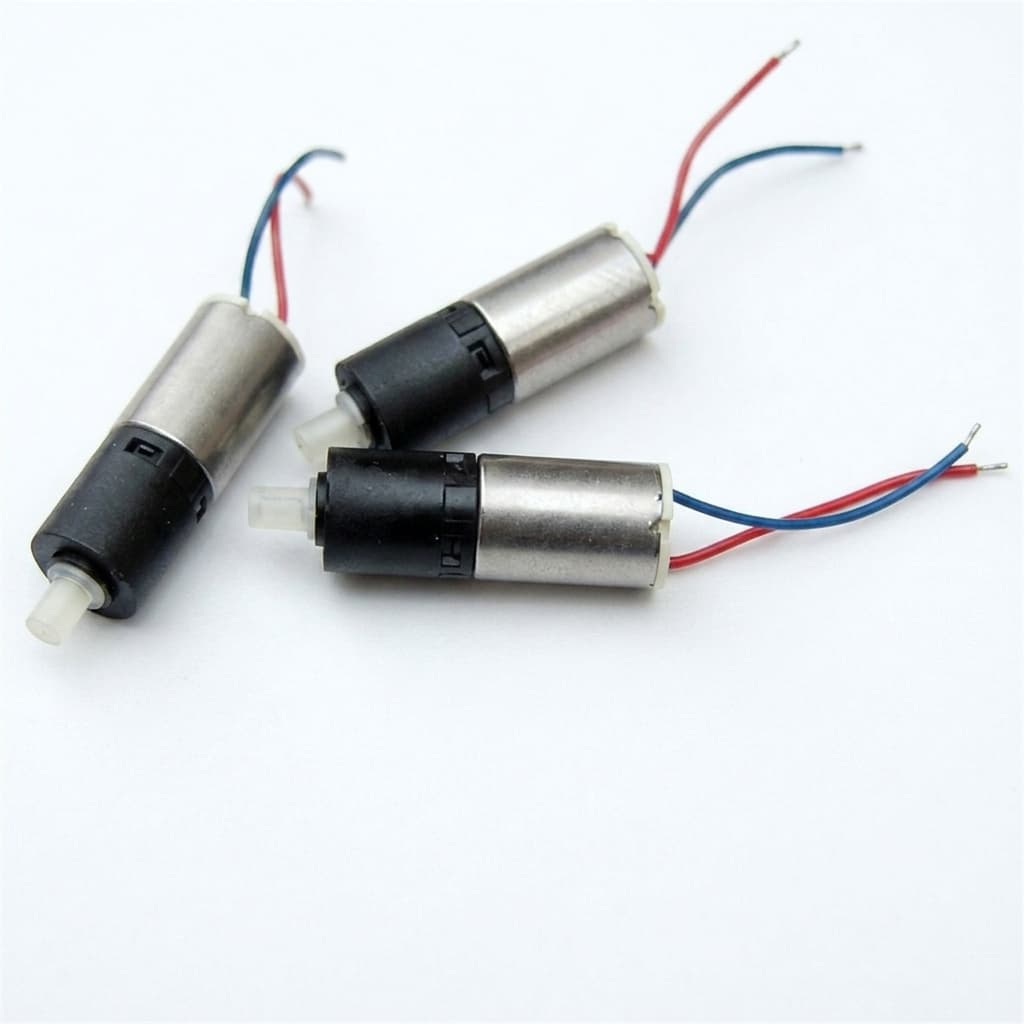
High-torque, responsive micro BLDC and gear motor sourcing for robotic joints, grippers, exoskeletons, and automated mechanisms.
Buyer check
Power-to-weight ratio: Optimized for mobile/wearable robotics
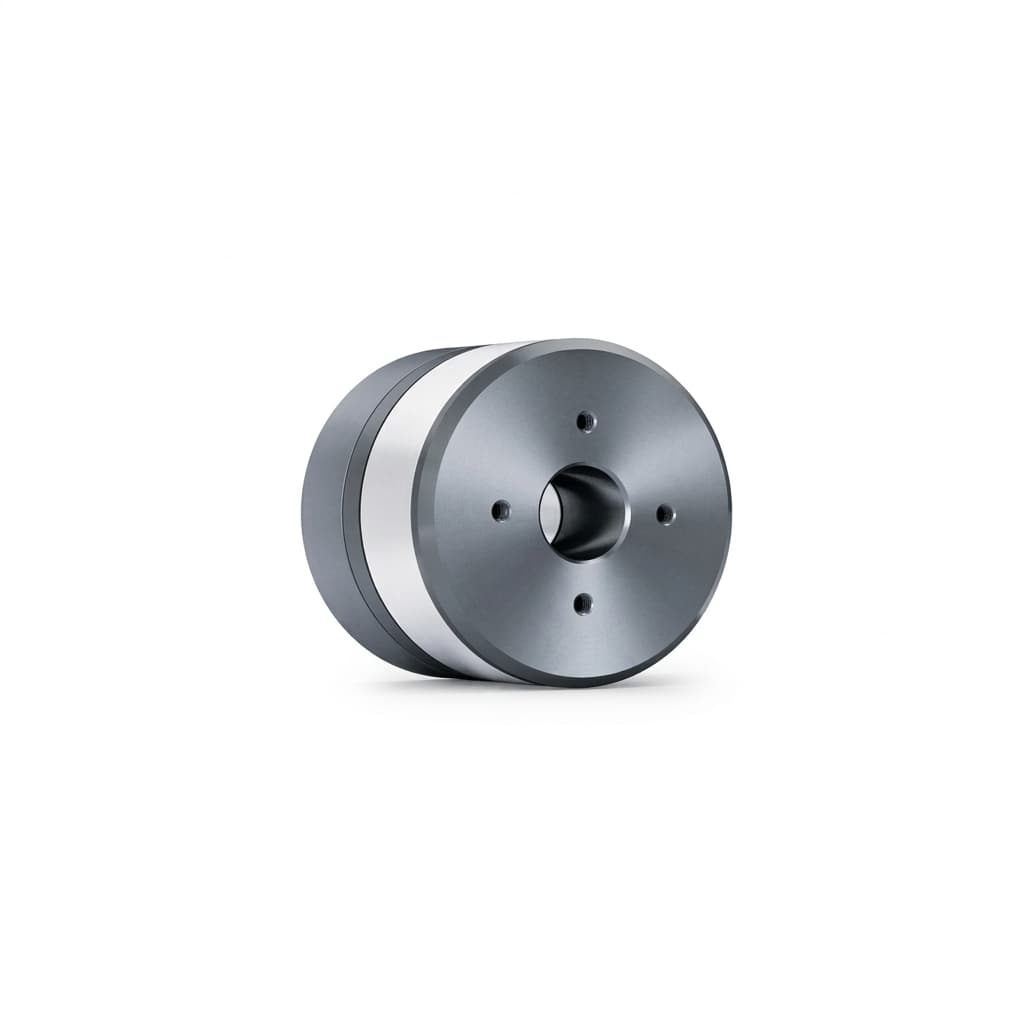
Low-vibration micro BLDC motors for optical equipment, laboratory devices, analyzers, and metrology instruments.
Buyer check
Speed ripple / Cogging: Low target defined by application and architecture
Practical buyer-side checklists, decision frameworks, and technical insights from our application engineering team.
Precision machining, automated winding, assembly, balancing, and validation support for high-mix, long-lifecycle micro BLDC repeat supply.
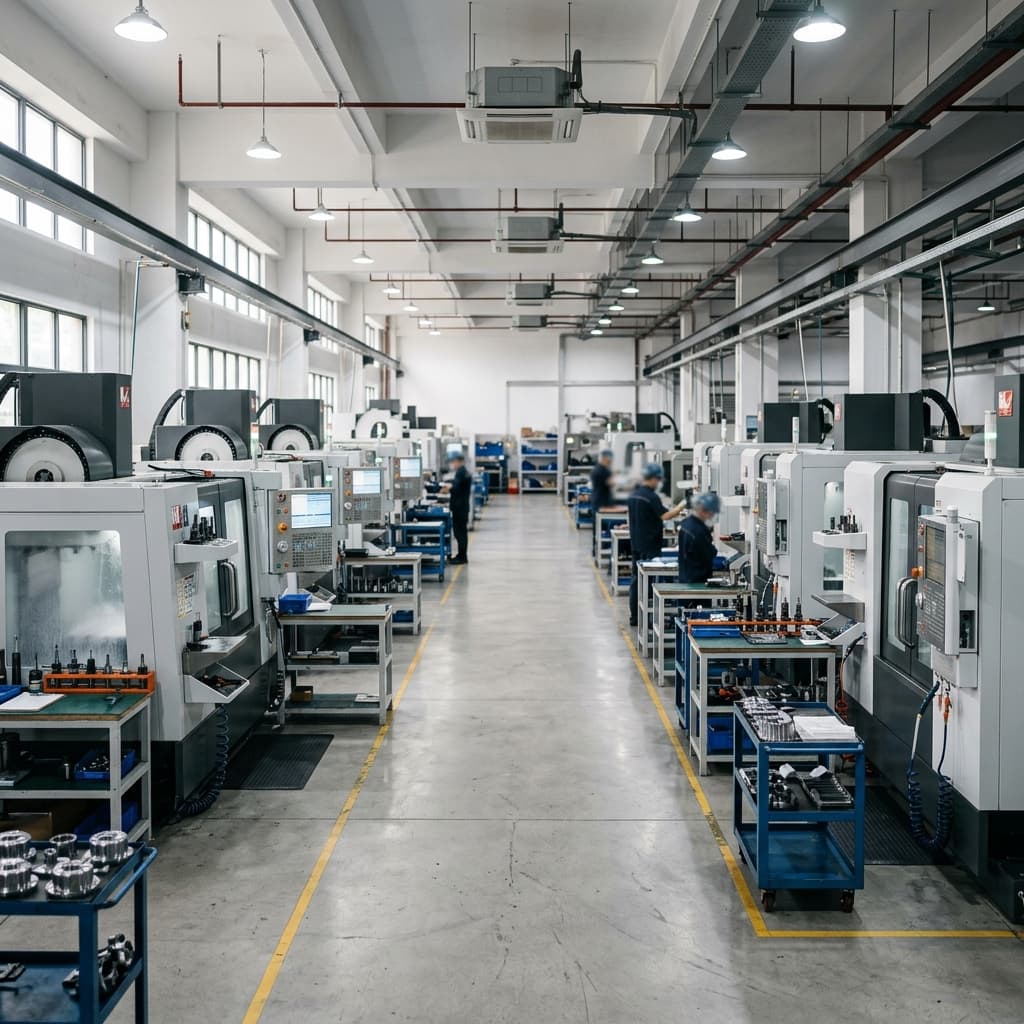
Representative manufacturing context, not facility, cleanroom, certification, validation, or audit proof.
FAQ
Share target size, voltage, speed, load, noise, life, control method, drawings, quantity, and timeline to receive engineering feedback and quotation support.
Inquiry Email
Include motor type, OD, voltage, speed, load, quantity, and destination.